优德官网 in the AIR

概述
日期
2023年06月20日
15:30 - 17:00
所在
运动行、Bilibili

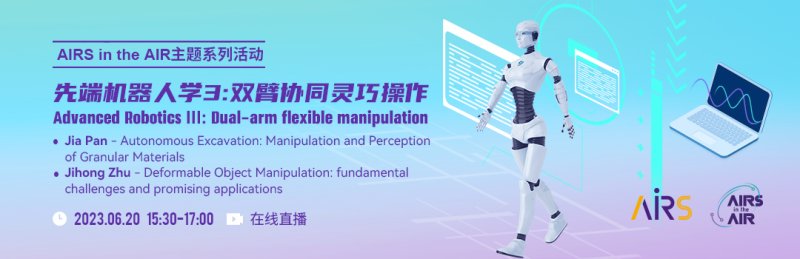
优德官网 in the AIR | 先端机械人学3:双臂协同灵巧操作

首页- 优德官网集团(中国)有限公司

先端机械人学系列前两期划分围绕“双足行走的控制和妄想”和“从人体行动剖析到人形机械人动力学”睁开, ,,,, ,本系列第三期约请到两位来自名校的青年学者围绕“双臂协同灵巧操作”划分分享感知和操控颗粒质料的自主挖掘机, ,,,, ,以及对可变形物体的操控的相关研究。。 。。。

第一位嘉宾Jia Pan是香港大学盘算机科学系副教授, ,,,, ,他的研究兴趣是机械人控制和学习, ,,,, ,在机械人自主导航和操作辖档挽域深耕多年, ,,,, ,效果斐然。。 。。。

第二位嘉宾Jihong Zhu是英国约克大学助理教授, ,,,, ,他还担当IROS、ICRA和RAL的副编辑, ,,,, ,他的研究兴趣是应用于机械人操作的基于视觉的控制和模拟学习。。 。。。

通过Bilibili(http://live.bilibili.com/22587709)加入。。 。。。

呼吸新鲜空气, ,,,, ,相识前沿科技!优德官网 in the AIR 为 优德官网 重磅推出的系列运动, ,,,, ,与您一起探索人工智能与机械人领域的前沿手艺、工业应用、生长趋势。。 。。。

  • 首页- 优德官网集团(中国)有限公司
    张添威
    优德官网智能机械人中心副研究员
    执行主席
  • 首页- 优德官网集团(中国)有限公司
    Jia Pan
    香港大学副教授
    Autonomous Excavation: Manipulation and Perception of Granular Materials

    Jia Pan is currently an associate professor in the Department of Computer Science at the University of Hong Kong. He received his BEng in Control Engineering from Tsinghua University, MEng in Pattern Recognition from the Chinese Academy of Sciences, and Ph.D. in Computer Science from the University of North Carolina at Chapel Hill. His research interests are robotic control and learning with a special focus on the development of autonomous robotic systems for navigation and manipulation.

    Autonomous excavators are an essential part of the goal of “building the robots that build the world”. One unique problem in autonomous excavation is how to deal with the granular materials like soils and sands, which is seldom studied in robotics. In this talk, we will present our recent work about how to achieve efficient manipulation of soils by optimizing the trajectory of the excavator’s bucket, and how to enable the excavator to be aware of the objects buried in the soils by using a proximity sensing mechanism based on jamming in granular materials.

  • 首页- 优德官网集团(中国)有限公司
    Jihong Zhu
    约克大学助理教授
    Deformable Object Manipulation: Fundamental Challenges and Promising Applications

    Zhu is a lecturer in robotics at the School of Physics, Engineering and Technology, University of York. He was a postdoctoral researcher jointly at Cognitive Robotics, TU Delft and Honda Research Institute, Europe working on assistive robots. He obtained his PhD from the University of Montpellier supported by the H2020 VERSATILE project. He is presently an Associate Editor for IROS, ICRA, and IEEE Robotics and Automation Letters. His main interest is vision-based control and imitation learning applied to robotic manipulation.

    What makes the manipulation of deformable objects difficult? In this talk, I will discuss some fundamental challenges introduced by object deformation and ways to tackle these challenges in my research. I will also present some of the promising applications of deformable object manipulation in both industrial and domestic settings.


时间 环节 嘉宾与问题

15:30-16:15

主题报告

Jia Pan , ,,,, , 香港大学
问题:Autonomous Excavation: Manipulation and Perception of Granular Materials  

16:15-17:00

主题报告

Jihong Zhu , ,,,, ,约克大学  
问题 :Deformable Object Manipulation: Fundamental Challenges and Promising Applications???????       

视频回首