优德官网 in the AIR

概述
日期
2023年09月26日
10:00 - 11:00
所在
运动行、Bilibili

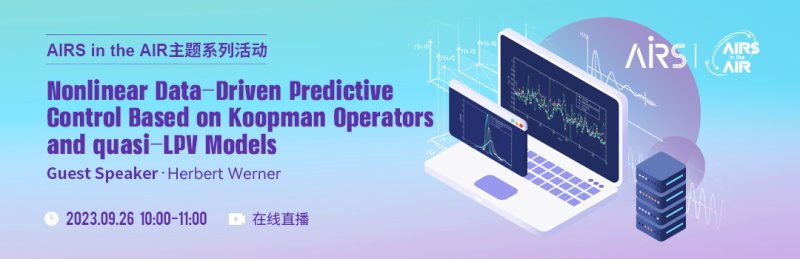
优德官网 in the AIR | 非线性数据驱动展望控制

首页- 优德官网集团(中国)有限公司

第58期优德官网 in the AIR约请德国汉堡工业大学Herbert Werner教授分享基于Koopman Operators和quasi-LPV模子的非线性数据驱动展望控制。。。。 。 。。

Herbert Werner是德国汉堡工业大学控制系统研究所所长 ,,, ,,,他的研究领域包括线性系统理论、鲁棒和增益调理控制系统、网络化控制系统 ,,, ,,,以及包括不确定性的非线性系统和时变系统的建模。。。。 。 。。

通过Bilibili(http://live.bilibili.com/22587709)加入。。。。 。 。。

呼吸新鲜空气 ,,, ,,,相识前沿科技!优德官网 in the AIR 为 优德官网 重磅推出的系列运动 ,,, ,,,与您一起探索人工智能与机械人领域的前沿手艺、工业应用、生长趋势。。。。 。 。。

  • 首页- 优德官网集团(中国)有限公司
    叮嘱
    优德官网常务副院长、特种机械人中心主任
    执行主席
  • 首页- 优德官网集团(中国)有限公司
    Herbert Werner
    德国汉堡工业大学教授、控制系统研究所所长
    Nonlinear Data-Driven Predictive Control Based on Koopman Operators and quasi-LPV Models

    Herbert Werner received the Dipl-Ing degree from the Ruhr University Bochum, Germany, the MPhil degree from the University of Strathclyde, UK, and the PhD degree from the Tokyo Institute of Technology, Japan, in 1989, 1991 and 1995, respectively. From 1995-98 he was with the Control Engineering Laboratory at the Ruhr University Bochum, Germany, and from 1999-2002 with the Control Systems Centre at UMIST, UK. Since 2002 he is head of the Institute of Control Systems at the Hamburg University of Technology, Germany. His research interests include linear systems theory, robust and gain-scheduled control systems, networked control systems, and modelling of uncertain, nonlinear and time-varying systems.

    Due to their considerable practical importance, fast nonlinear predictive control schemes have been receiving considerable attention over the last two decades. In this talk we present a recently developed approach to nonlinear MPC that is based on a quasi-Linear Parameter-Varying (qLPV) model of the plant. The nonlinear optimization problem is solved by iteratively optimizing the input sequence for an LTV system (using warm starts, this typically amounts to solving one QP per sampling period). Stability can be guaranteed via terminal constraints.

    When a first-principles model of the nonlinear plant is available, a suitable qLPV model can be constructed using a velocity-linearisation approach. Alternatively, when a first-principles model is not available, we present a data-driven approach to construct a qLPV model that is based on a truncated Koopman operator representation and can be updated online. The real-time capability of the proposed method is illustrated with experimental results on an arm-driven inverted pendulum, a robot manipulator and a control moment gyroscope.