优德官网 in the AIR

概述
日期
2023年09月25日
10:00 - 12:00
所在
运动行、Bilibili

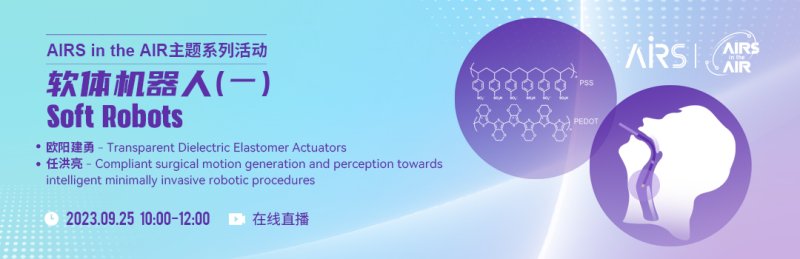
优德官网 in the AIR | 软体机械人(一)

首页- 优德官网集团(中国)有限公司

软体机械人由柔软质料组成,,,,,具有质量轻、与情形接触碰撞力小等特点,,,,,能够顺应种种非结构化情形,,,,,与人交互时越发无邪清静,,,,,近年来受到了学界与业界普遍关注。。。 。。 。。

今年“软体机械人”系列讲座准期而至,,,,,依旧约请本事域最顶尖的专家学者,,,,,与各人在优德官网 in the AIR相聚交流。。。 。。 。。第一期我们约请新加坡国立大学质料科学与手艺系欧阳建勇副教授和香港中文大学电子工程学系任嘹亮副教授划分分享透明介电弹性体致动器和软体智能微创机械人相关研究。。。 。。 。。

通过Bilibili(http://live.bilibili.com/22587709)加入。。。 。。 。。

呼吸新鲜空气,,,,,相识前沿科技!优德官网 in the AIR 为 优德官网 重磅推出的系列运动,,,,,与您一起探索人工智能与机械人领域的前沿手艺、工业应用、生长趋势。。。 。。 。。

  • 首页- 优德官网集团(中国)有限公司
    朱建
    优德官网 项目认真人、香港中文大学(深圳)副教授
    执行主席
  • 首页- 优德官网集团(中国)有限公司
    欧阳建勇
    新加坡国立大学副教授
    Transparent Dielectric Elastomer Actuators

    欧阳建勇教授划分于清华大学,,,,,中国科学院化学所和日天职子科学研究所获得学士,,,,,硕士和博士学位。。。 。。 。。现任职于新加坡国立大学质料科学与手艺系,,,,,其研究团队主要集中在柔性电子质料和器件,,,,,包括本征导电聚合物、半导体聚合物、和纳米复合质料。。。 。。 。。主要研究效果包括发明了天下上第一个(聚合物/纳米离子)忆阻存储器(2004),,,,,天下上第一个(离子/电子)混淆热电转换器 (2020), 天下上第一个可粘附的本征导电聚合物(2020),,,,,发明了光增强塞贝克效应(2021),,,,,天下上第一次把柔性应变传感器用于食物加工监测(2021),,,,,首次发明了高分子质料的延展化(2022),,,,,发明了多种要领来提高导电聚合物的电导率和热电性能和离子导体的热电性能并多次刷新了可溶液加工的导电聚合物的电导率,,,,,聚合物的热电性能和离子导体的热电性能的天下纪录。。。 。。 。。

    Dielectric elastomer actuators (DEAs) can have controllable actuation by applying an electrical voltage. The principle is the mechanical deformation of a dielectric polymer film caused by the Coulomb attraction between the two electrodes. This requires the electrodes to be compliant. The electrode materials should be thus conductive and stretchable. Conventionally, carbon grease is used as the compliant electrodes of DEAs. However, carbon grease is in liquid state, and it is not transparent. Here, I will present our work in developing transparent conducting polymers as the compliant electrodes of DEAs. At first, we developed various methods to greatly enhance the conductivity of PEDOT:PSS that is the most successful conducting polymer in terms of practical application and demonstrated its application as flexible transparent electrodes of optoelectronic devices. Then, we developed approaches to notably improve the mechanical stretchability of PEDOT:PSS, inlcuding the blend formation, plasticization and ductilization. Finally, I will show the application of the stretchable transparent PEDOT:PSS with high conductivity as the transparent solid electrodes of DEAs. They can have important application in many areas, such as camouflage soft robots and tunable soft lenses.

  • 首页- 优德官网集团(中国)有限公司
    任嘹亮
    香港中文大学副教授
    Compliant surgical motion generation and perception towards intelligent minimally invasive robotic procedures

    Hongliang Ren received his Ph.D. in Electronic Engineering (Specialized in Biomedical Engineering) from The Chinese University of Hong Kong (CUHK) in 2008. He has served as an Associate Editor for IEEE Transactions on Automation Science & Engineering (T-ASE) and Medical & Biological Engineering & Computing (MBEC).  He has navigated his academic journey through Chinese University of Hong Kong, Johns Hopkins University, Children’s Hospital Boston, Harvard Medical School, Children’s National Medical Center, United States, and National University of Singapore (NUS). 

    His areas of interest include biorobotics, intelligent control, medical mechatronics, soft continuum robots, soft sensors, and multisensory learning in medical robotics. He is the recipient of NUS Young Investigator Award and Engineering Young Researcher Award, IAMBE Early Career Award 2018, Interstellar Early Career Investigator Award 2018, ICBHI Young Investigator Award 2019, and Health Longevity Catalyst Award 2022 by NAM & RGC.
    Minimally Invasive Surgeries (MIS) emerging in modern medical treatment have brought new opportunities and challenges for procedure-specific surgical motion generation and the associated motion understanding, which are the foundation of intelligent robotic manipulation and guiding interventions. Image-guided robotic surgery is expected to increase the precision, flexibility, and repeatability of surgical procedures but poses challenges for system development. This talk will highlight our recent developments in dexterous robotic motion generation with motion perception towards image-guided minimally invasive procedures. The procedure-specific telerobotic surgical systems can assist surgeons in performing dexterous manipulations using continuum motion generation mechanisms with variable stiffness and context awareness.


时间 环节 嘉宾与问题

10:00-11:00

主题报告

欧阳建勇 ,,,,, 新加坡国立大学
问题:Transparent Dielectric Elastomer Actuators  

11:00-12:00

主题报告

任嘹亮 ,,,,,香港中文大学???????  
问题 :Compliant surgical motion generation and perception towards intelligent minimally invasive robotic procedures

视频回首