优德官网 in the AIR

概述
日期
2023年05月16日
15:00 - 16:30
所在
运动行、Bilibili

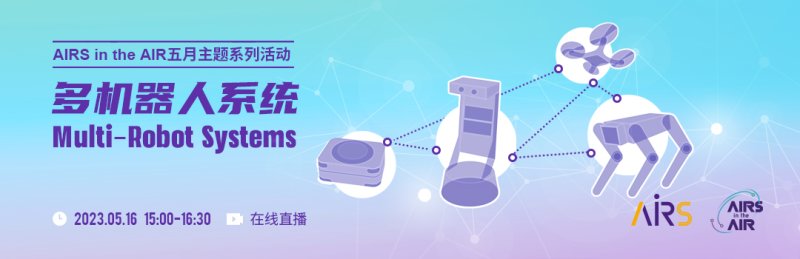
优德官网 in the AIR | 多机械人系统(一)

首页- 优德官网集团(中国)有限公司

多机械人系统由众多自力的机械人个体组成,,,,,,,个体间可自主地协同相助,,,,,,,相比单个机械人具有更高的效率、可扩展性和容错能力,,,,,,,正在改变各行各业应对重大使命的方法,,,,,,,在物流运输、工业生产和情形监测等诸多领域取得了普遍应用。。 。。。

优德官网 in the AIR 五月系列运动约请天下顶级学者围绕“多机械人系统”开展讲座,,,,,,,第一期将在5月16日(周二)举行。。 。。。

第一位报告嘉宾 Martin Saska 是捷克理工大学研究员、多机械人系统实验室主任,,,,,,,他在 IJRR、AURO、ICRA 等期刊和聚会揭晓超200篇论文,,,,,,,他的团队在MBZIRC 2017、MBZIRC 2020和 DARPA SubT 竞赛中赢得了多项机械人挑战赛。。 。。。

第二位报告嘉宾 Luis Merino 是巴勃罗·德·奥拉维德大学(UPO)副教授、UPO 效劳机械人实验室主任,,,,,,,担当 Image and Vision Computing、RA-L、ICRA 等期刊和聚会编辑。。 。。。他向导团队加入多个协作机械人系统相关项目,,,,,,,曾获 MBZIRC 2020总决赛第三名。。 。。。

通过Bilibili(http://live.bilibili.com/22587709)加入。。 。。。

呼吸新鲜空气,,,,,,,相识前沿科技!优德官网 in the AIR 为 优德官网 重磅推出的系列运动,,,,,,,与您一起探索人工智能与机械人领域的前沿手艺、工业应用、生长趋势。。 。。。

  • 首页- 优德官网集团(中国)有限公司
    林天麟
    优德官网 智能机械人中心主任、香港中文大学(深圳)助理教授
    执行主席
  • 首页- 优德官网集团(中国)有限公司
    胡君杰
    优德官网 智能机械人中心助理研究员
    主持人
  • 首页- 优德官网集团(中国)有限公司
    Martin Saska
    捷克理工大学研究员
    Research of Tightly Cooperating Aerial Vehicles in Real-world Environment

    Martin Saska received his MSc. degree at Czech Technical University in Prague, 2005, and his Ph.D. degree at University of Wuerzburg, Germany, within the PhD program of Elite Network of Bavaria, 2009. Since 2009, he is a research fellow at Czech Technical University in Prague, where he founded and heads the Multi-robot Systems lab and co-founded Center for Robotics and Autonomous Systems with more than 70 researchers cooperating in robotics. He was a visiting scholar at University of Illinois at Urbana-Champaign, USA in 2008, and at University of Pennsylvania, USA in 2012, 2014 and 2016, where he worked with Vijay Kumar's group within GRASP lab. He is an author or co-author of >150 publications in peer-reviewed conferences with multiple best paper awards and more >50 publications in impacted journals, including IJRR, AURO, JFR, ASC, EJC, with >5500 citations indexed by Scholar and H-index 41. His team won multiple robotic challenges in MBZIRC 2017, MBZIRC 2020 and DARPA SubT competitions.

    Using large teams of tightly cooperating Micro Aerial Vehicles (MAVs) in real-world (outdoor and indoor) environments without precise external localization such as GNSS and motion capture systems is the main motivation of this talk. I will present some insights into the research of fully autonomous, bio-inspired swarms of MAVs relying on onboard artificial intelligence. I will discuss the important research question of whether the MAV swarms can adapt better to localization failure than a single robot. In addition to the fundamental swarming research, I will be talking about real applications of multi-robot systems such as indoor documentation of large historical objects (cathedrals) by formations of cooperating MAVs, a cooperative inspection of underground mines inspired by the DARPA SubT competition, localization and interception of unauthorized drones, aerial firefighting, radiation sources localization, power line inspection, and marine teams of cooperating heterogeneous robots.

  • 首页- 优德官网集团(中国)有限公司
    Luis Merino
    巴勃罗·德·奥拉维德大学副教授
    Active Perception for Exploration with Multiple Robots using Information Theory

    I am Associate Professor at the School of Engineering of the Universidad Pablo de Olavide (UPO), Seville, Spain, where I lead the Service Robotics Laboratory. I led the creation of the Systems Engineering and Automation division of UPO's School of Computer Science, where I have been Vice-Dean for five years.

    I hold a Ph.D. degree on Robotics, from the University of Seville. This thesis was awarded with the ABB Award to the Best Doctoral Dissertation on Robotics 2007 in Spain, given by the Spanish Committee of Automation (CEA, Robotics Group).

    My main research lines deal with cooperative robotic systems, including multi-robot systems and the cooperation between robots and persons. In these lines I have made contributions on new localization and navigation techniques, cooperative perception methods, decision making under uncertainties, and human-robot collaboration in social settings. I am leading or have led UPO’s team as PI in more than 15 international and national projects in these lines. Our group participated in the Mohammed Bin Zayed International Robotics Challenge (MBZIRC) in 2020, where we finished third in the Grand Finale of the competition.

    I serve as Associated Editor of the Image and Vision Computing and IEEE Robotics and Automation Letters journals, and of ICRA and IROS, the two flagship conferences on robotics.
    The talk will deal with the exploration problem using multiple robots. This problem consists of reconstructing, in the most efficient way possible, a spatial model of some phenomenon of interest, such as a 2D/3D map of an area, the spatial distribution of the concentration of a gas or a map of a magnetic field, using measurements from the robot's sensors. Efficiency in this context means obtaining the model with the least possible "effort" by the robots, typically in the shortest possible time, or by performing the minimum number of measurements necessary. If probabilistic models are used, metrics derived from Information Theory can be employed to determine those actions that will be most effective when carrying out the perception task. Specifically, in the talk Gaussian Processes will be considered as those models, and active perception algorithms will be presented for efficient exploration in these cases using a robot. Likewise, the talk will discuss how to extend these techniques to the case of multiple robots efficiently and taking into account the kinematic and communications restrictions present.

时间 环节 嘉宾与问题

15:00-15:40

主题报告

Martin Saska,,,,,,,捷克理工大学
问题:Research of Tightly Cooperating Aerial Vehicles in Real-world Environment

15:40-16:30

主题报告

Luis Merino,,,,,,,巴勃罗·德·奥拉维德大学
问题:Active Perception for Exploration with Multiple Robots using Information Theory      

视频回首