优德官网 in the AIR

概述
日期
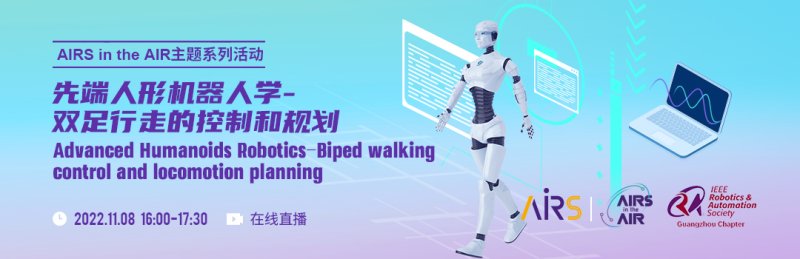
2022年11月08日
16:00 - 17:30
所在
运动行、ZOOM

优德官网 in the AIR | 先端人形机械人学-双足行走的控制和妄想

首页- 优德官网集团(中国)有限公司

人形机械人虽然具有仿人的形态,,,,,但在现真相形中想实现像人类一样无邪、快速的运动还具有很大的挑战。。。。。。。。本期 优德官网 in the AIR 由 优德官网 和 IEEE 广州分会机械人与自动化分部团结举行,,,,,将约请两位机械人领域资深学者围绕人形机械人的控制和妄想带来主题报告,,,,,划分从攻击感知和双足行走两方面展示人形机械人的最新研究希望。。。。。。。。

第一位报告嘉宾王玉全是荷兰马斯特?赫特?学助理教授,,,,,瑞典皇家理工学院机械人与盘算机视觉博士,,,,,他的研究重点是??? ??榛臀扌暗目刂粕杓疲,,,,以实现鲁棒、清静和易于使用的机械人系统。。。。。。。。

第二位报告嘉宾 Milutin Nikoli? 是诺维萨德大学手艺科学学院副教授,,,,,诺维萨德大学机械人博士。。。。。。。。他的研究领域包括机械人全身运动综合、行走模式天生、接触稳固性标准、多系一切动力学和机械人操作与抓取。。。。。。。。

点击链接报名加入:http://hdxu.cn/1facs,,,,,或通过ZOOM(https://us02web.zoom.us/meeting/register/tZAudeirpzwvGNN2KD3P520bsq4XgyerDsXt)/Bilibili(http://live.bilibili.com/22587709)加入。。。。。。。。

呼吸新鲜空气,,,,,相识前沿科技!优德官网 重磅推出 系列运动 优德官网 in the AIR。。。。。。。。每周二与您相约线上,,,,,一起探索人工智能与机械人领域的前沿手艺、工业应用、生长趋势。。。。。。。。

  • 首页- 优德官网集团(中国)有限公司
    钱辉环
    优德官网 副院长、香港中文大学(深圳)助理教授、IEEE 广州分会机械人与自动化分部副主席
    执行主席
  • 首页- 优德官网集团(中国)有限公司
    张添威
    优德官网 智能机械人中心副研究员
    主持人
  • 首页- 优德官网集团(中国)有限公司
    Yuquan Wang
    荷兰马斯特?赫特?学助理教授
    Impact-aware humanoid control

    Wang, Yuquan received his Bachelor's degree in Mechanical Engineering and Automation from Beijing Jiao Tong University in 2008, a M.S. degree in Systems, control and robotics, and a Ph.D. degree in Robotics and computer vision from the Robotics, Perception, and Learning (RPL) at the Royal Institute of Technology (KTH), Stockholm, Sweden, in 2010 and 2016 respectively. He worked as a research assistant at the Eindhoven University of Technology in 2011; as a Post-doc researcher in the Sustainable Production Systems group at KTH between 2016 and 2018. Before he joined Maastricht University in September 2022, he served as a Post-doc researcher at CNRS-UM, LIRMM. His research focuses on modular and flexible control design that enables robust, safe, and easy-to-use robotic systems.

    Almost all the robots fear impacts. Without accurate impact mechanics, robots typically cautiously approach rigid contacts at a near-zero velocity. Despite the human-like morphology, the humanoid robots can not apply human-like swift motion in a contact-rich environment. Thus, humanoid robots rarely, if not impossible, impress the general public and solve practical applications. Modeling and controlling the impact event is challenging. Impacts cause sudden changes in the velocities and torques. These state jumps can severely damage the robot hardware, enable un-deterministic contact mode (e.g., sliding or sticking), and, most importantly, break the standing stability. We envision future humanoid robots not worrying about impacts and can assist humans through energetic physical contact. This talk will go through the latest impact mechanics modeling and control. In particular, the state-of-the-art usually focuses on planning periodic impacts without ensuring the hardware/control feasibility during the time interval before and after the impact event. We base our control design on the set of all the candidate frictional impulses and enable hardware-affordable dynamic motion. The on-purpose impact event becomes deterministic and undercontrolled. Preliminary experiments employing the Panda manipulator and the humanoid robot HRP-4 proved that impact awareness significantly improves the robot's manipulation efficiency without breaking hardware or falling.

  • 首页- 优德官网集团(中国)有限公司
    Milutin Nikoli?
    诺维萨德大学副教授
    Advanced Humanoid Robotics – Biped walking control and locomotion planning

    Milutin Nikoli? received his M.Sc in Mechatronics and a Ph.D. degree in Robotics from the University of Novi Sad, Serbia in 2008 and 2015 respectively. He currently works as an Associate professor of Robotics at the University of Novi Sad, Faculty of Technical Sciences, Chair of Mechatronics, Robotics, and Automation. His field of research includes whole-body motion synthesis, walking pattern generation, contact stability criteria, multi-body system dynamics and robot manipulation and grasping. He spent 18 months at Nakamura-Yamamoto lab, the University of Tokyo in Japan, as a Project assistant professor working on human motion capturing and analysis. Nikoli? was also working as a research associate at NTU Singapore, TU Technikum Wien, and UMIT, Hall in Tyrol. Nikoli? has industry experience, working as a principal robotic arm manipulation engineer at the Aeolus robotics, where he developed novel approaches in arm calibration and whole-body motion planning. He also gave several guest lectures at well-established robotics laboratories, some of which are Nakamura & Yamamoto Lab University of Tokyo Japan, Biorobotics Laboratory, EPFL, Switzerland, Vislab at Instituto Superior Técnico in Lisbon Portugal, Automation, Biocybernetics and Robotics Department at Jo?ef Stefan Institute….
    The human environment is tailor to way human moves around. As a result the robot that operates in such an environment has to walk. Bipedal walking is a task that’s very easy for humans, but very hard for robots, mainly because standing robot is underactuated and inherently unstable. During the motion planning and motion execution phase special attention must be given to contact forces acting on the robot’s feet. The contact between the feet and the ground has to be constantly maintained to ensure stable walking. In this lecture we will start from walking stability indicator ZMP, introduced more than 50 years ago and go up to state of the art walking stability indicators, capable of handling inclined surfaces and multiple contacts. We will take care about the underlying physical constraints and mention appropriate planning and control approaches that are built to fulfill them.

时间 环节 嘉宾与问题

16:00-16:40

主题报告

Yuquan Wang,,,,,荷兰马斯特?赫特?学 
问题:Impact-aware humanoid control

16:40-17:30

主题报告

Milutin Nikoli?,,,,,诺维萨德大学
 问题:Advanced Humanoid Robotics – Biped walking control and locomotion planning      

视频回首