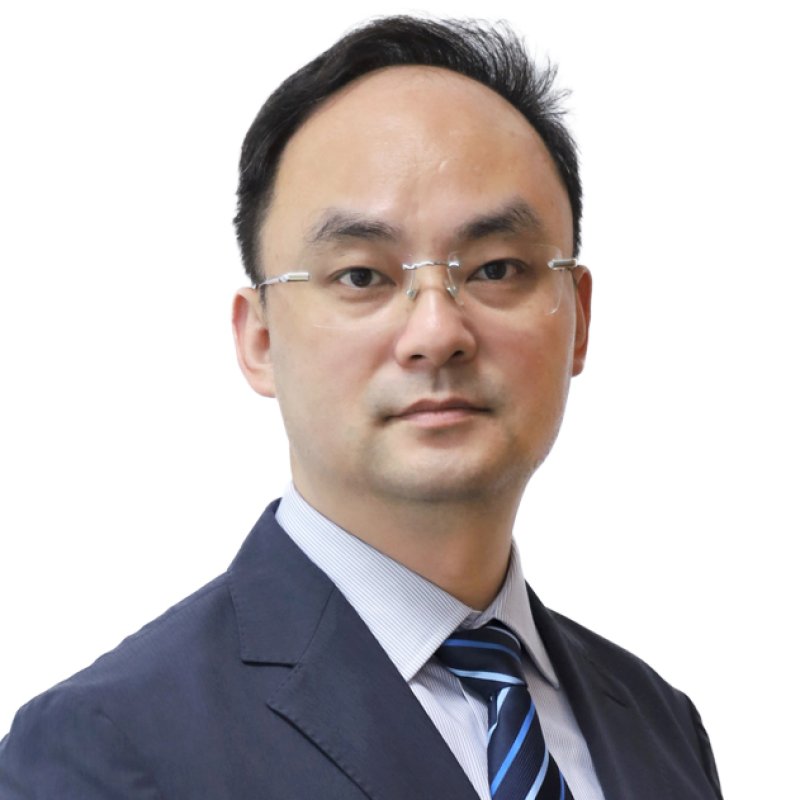
Dr. Ding Ning, Research Fellow, Senior Engineer, received his PhD from the Department of Mechanical and Automation Engineering at The Chinese University of Hong Kong (CUHK). His research focuses on special robots and computer vision. He currently serves as the Executive Associate Director of the Shenzhen Institute of Artificial Intelligence and Robotics for Society (优德官网), Deputy Director of the Institute of Robotics and Intelligent Manufacturing, The Chinese University of Hong Kong, Shenzhen, Director of the Guangdong Innovation Center for Embodied Intelligent Robotics, the Engineering Technology Research Center, and the Engineering Research Center, and Director of the Joint Laboratory of the Department of Education of Guangdong Province and Guangdong, Hong Kong and Macao Universities on Urban Maintenance Robots.
Dr. Ding Ning concurrently serves as a member of the Special Equipment Robot Sub-technical Committee of SAC/TC591/SC1 and SC5 National Robot Standard Committee, a member of MIIT/TC8 Technical Committee for Humanoid Robots and Embodied Intelligence Standardization, a registered expert of ISO/TC299/WG16, and a member of standardization committees in various industry associations including NEA/TC35, TC41, CEEIA/TC50, CASEI, CSEE, China Electricity Council, Electrical Engineering, Electrical Equipment Industry, and Special Equipment, Deputy Director of the Intelligent Vehicles and Robots Committee of the China Instrument and Control Society (CIS), Editorial Board Member of the Chinese Journal of Scientific Instrument, Deputy Secretary-General and Council Member of the Guangdong Artificial Intelligence and Robotics Alliance, Council Member of the Society, Consultant Expert of the Standing Committee of Shenzhen Municipal People's Congress, Deputy Director of Shenzhen Artificial Intelligence Standardization Committee, Deputy Director of Shenzhen Artificial Intelligence Ethics Review Committee, Member of Hehu Think Tank in Longgang District of Shenzhen, Senior Professional Manager of Vocational Skills in Shenzhen, and Chief Curator of UABB 2025 Bi-City Biennale of Urbanism\Architecture (Shenzhen & Hong Kong).
He has led major scientific research projects including the National Natural Science Foundation of China (NSFC), Guangdong Provincial Key R&D Program, Guangdong Natural Science Foundation, Shenzhen Key Basic Research Program, Sustainable Development Special Project, Marine Special Project and Strategic Research Project. His research covers embodied Intelligence foundation models, embodied intelligence robot systems, and the development of special robots for operation, maintenance and inspection of urban infrastructure such as power facilities, bridges and pipelines. He has published more than 100 papers in international conferences and journals, been granted more than 100 authorized invention patents and 1 international patent, and has led or participated in the formulation and publication of over 10 national standards in the robotics field. Recognized as a Guangdong Leading Talent, Shenzhen Overseas High-Level Talent and Shenlong Talent, he has earned many prestigious awards, including: IEEE IROS 2021 Best Application Paper Award and finalist of Best Paper Award on Robot Mechanisms and Design; the 2023 China Mechanical Industry Science and Technology Progress Award; the 2023 China Overseas Talents Innovation and Entrepreneurship Award, the Pioneer Cup Future Technology Innovation Competition Award; the 2024 Wu Wenjun Artificial Intelligence Science and Technology Progress Award, and the 2025 China Instrument and Control Society Science and Technology Progress Award.
He participated in drafting many national/industry standards:
1. Terminology for Special Robots (GB/T 36239-2018), Lead Author, issued in January 2019
2. Classification, Symbols and Markings for Special Robots (GB/T 36321-2018), Lead Author, issued in January 2019
3. General Technical Requirements for Motion Rehabilitation Training Robots (GB/T 37704-2019), Contributing Author, issued in March 2020
4. General Technical Requirements for Ground Debris Search and Rescue Robots (GB/T 37703-2019), Contributing Author, issued in March 2020
5. Terminology for Power Robots (GB/T 39586-2020), Contributing Author, issued in July 2021
6.Hydrostatic Pressure Test Methods for Underwater Robots and Their Components (GB/T 43849-2024), Contributing Author, issued in May 2024
7. Performance and Test Methods for Legged Robots (GB/T 44251-2024), Contributing Author, issued in July 2024
8.Classification and Reference Architecture for Cloud Platforms of Service Robots (GB/T 45301-2025), Contributing Author, issued in February 2025
9.Vocabulary of Robots (GB/T 12643-2025), Contributing Author, issued in February 2025
10. General Technical Requirements for 3D Vision-Guided Systems of Industrial Robots (GB/T 45501-2025), Contributing Author, issued in March 2025
11.General specification for self-driven in-line inspection robot (GB/T 46366-2025),Contributing Author, issued in October 2025
1.Zhenliang Zheng, Ning Ding*, Herbert Werner, Feng Ren, Yongyuan Xu, Wenchao Zhang, Xiaoli Hu, Jianguo Zhang, Tin Lun Lam*, “CCRobot-S: A Robotic Cable-Climbing Squad Collaborating for Fast Inspection and Heavy-Duty Maintenance”, IEEE Transactions on Robotics, 2025.
2.Zhenliang Zheng, Chao Wang, Xiaoli Hu, Lun Zhang, Wenchao Zhang, Yongyuan Xu, Pengfei Liu, Xufang Pang, Tin Lun Lam*, Ning Ding*, “Developing a climbing robot for stay cable maintenance with security and rescue mechanisms”, Journal of Field Robotics, 2025. (Inside Back Cover Image)
3.Zhenliang Zheng, Yongyuan Xu, Xuchun He, Tin Lun Lam*, Ning Ding*, A Cascaded Strategy with Embodied Artificial Intelligence: Forward Kinematics Solutions for CCRobot‐S, Journal of Field Robotics, 2025. (Cover Image)
4.Shengkai Liu, Jian Jiao, Ning Ding*, Tao Mei, “Dynamic Modeling Incorporating Water Damping for a Fiber-Reinforced Soft Actuator Based on Euler–Bernoulli and Cosserat Rod Theories”, IEEE/ASME Transactions on Mechatronics, 2024.
5.Shengkai Liu, Jian Jiao, Ning Ding*, Tao Mei, “Dynamic Modeling Incorporating Water Damping for a Fiber-Reinforced Soft Actuator Based on Euler–Bernoulli and Cosserat Rod Theories”, IEEE/ASME Transactions on Mechatronics, 2024.
6.Xufang Pang, Feng Li, Hongjie Zhuang, Ning Ding*, Xiaopin Zhong, Shengfeng He, Wenxi Liu, Bo Jiang, “Upright-Net+: Enhanced Learning of Upright Orientation for 3D Point Clouds”, IEEE Transactions on Visualization and Computer Graphics, 2025.
7.Xufang Pang, Feng Li, Ning Ding*, Xiaopin Zhong*, "Upright-Net: Learning Upright Orientation for 3D Point Cloud", IEEE/CVF CVPR 2022.
8.Zonggao Mu*, Luyang Zhang, Lei Yan, Zixuan Li, Ruichun Dong, Chengjiang Wang, Ning Ding, “Hyper-redundant manipulators for operations in confined space: Typical applications, key technologies, and grand challenges“, IEEE Transactions on Aerospace and Electronic Systems, 2022.
9.Xuan Xia, Xizhou Pan, Nan Li, Xing He, Lin Ma, Xiaoguang Zhang, Ning Ding*, “GAN-based anomaly detection: A review”, Neurocomputing, 2022. (Highly Cited Paper)
10.Zhenliang Zheng, Ning DING* , Huaping Chen, Xiaoli Hu, Sarsenbek Hazken, Ziya Wang, “CCRobot-V: A Silkworm-Like Cooperative Cable-Climbing Robotic System for Cable Inspection and Maintenance”, IEEE ICRA 2022.
11.Wenchao Zhang, Zhenliang Zheng, Ning Ding*, “CCRobot-IV-F: a Ducted-fan-driven Flying-type Bridge Stay Cable Climbing Robot”, IEEE IROS 2021. (Best Application Paper Award, Best Mechanism and Design Award finalist)
12.Zhenliang Zheng, Wenchao Zhang, Huaping Chen, Ning Ding*, “CCRobot-IV: an Obstacle-free Split-type Quad-ducted Propeller-driven Bridge Stay Cable Climbing Robot”, IEEE IROS 2021, RAL.
13.Ning Ding*, Zhenliang Zheng and Junlin Song, “CCRobot-III: a Wire-driven Palm-based Cable Climbing Robot for Inspection on the Cable-stayed Bridge”, IEEE ICRA 2020.
14.Zhenliang Zheng, Ning Ding*, “Design and Implementation of the CCRobot-II: a Palm-based Cable Climbing Robot for Inspection on the Cable-stayed Bridge”, IEEE ICRA 2019.
15.Zhenliang Zheng, Sufeng Hu and Ning Ding*, "A Biologically Inspired Cable Climbing Robot: CCRobot - Design and Implementation”, IEEE ROBIO 2018.
16.Zhenliang Zheng, Xiaoqiang Yuan, Huanhui Huang, Xiao Yu, Ning Ding*. "Mechanical design of a cable climbing robot for inspection on a cable-stayed bridge", IEEE WCICA 2018.