优德官网 in the AIR

Overview
Date
May 24, 2022
15:00 - 16:35
Venue

运动行

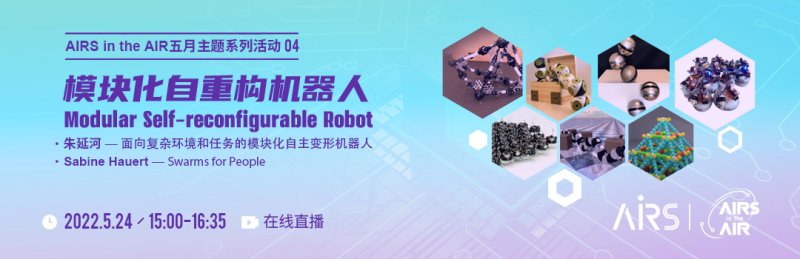
优德官网 in the AIR | Modular Self-reconfigurable Robot (Session 4)

首页- 优德官网集团(中国)有限公司

Modular self-recon?gurable robots have become a hot research topic in recent years. It is a robot system composed of isomorphic units, which can be changed into appropriate configurations according to different tasks and environments. It is especially suitable for changing environment and complex operation tasks. It has broad application prospects in the fields of rescue, anti-terrorism reconnaissance, space exploration and so on.

In order to promote the theoretical and technological innovation and academic exchanges in the field of modular self-recon?gurable robots at home and abroad, Shenzhen Institute of Artificial Intelligence and Robotics for Society (优德官网) is scheduled to hold "Modular Self-recon?gurable Robots" Series Talk in May 2022. 

Join the event on May 24 through this link: http://hdxu.cn/VLj6g

  • 首页- 优德官网集团(中国)有限公司
    Tin Lun Lam
    Director of Center for Intelligent Robots at 优德官网; Assistant Professor at The Chinese University of Hong Kong, Shenzhen
    Executive Chair
  • 首页- 优德官网集团(中国)有限公司
    朱延河
    哈尔滨工业大学教授
    面向重大情形和使命的模??? ?榛灾鞅湫位等

    朱延河教授于2004年在哈尔滨工业大学获得机械电子工程专业博士学位, ,,, ,,,现任机械人手艺与系统国家重点实验室副主任, ,,, ,,,哈尔滨工业大学教授、博士生导师。。。。。。。国家优异青年科学基金获得者, ,,, ,,,入选国家高条理人才特殊支持妄想科技立异领武士才。。。。。。。恒久从事机械人相关科学研究与教学事情, ,,, ,,,主要研究偏向包括模??? ?榛灾毓够等恕⒖梢伦磐夤趋阑等恕⒓饲樾畏役机械人等。。。。。。。作为认真人主持国家自然科学基金重点项目、国家重点研发妄想、国家核聚变能研究生长专项、载人航天重大工程项目等20余项, ,,, ,,,研究效果乐成应用于载人航天、核电运维、抢险救援、医疗康复等军民领域。。。。。。。揭晓主要学术论文120余篇, ,,, ,,,授权国际/中国发明专利110余项, ,,, ,,,获国家级设计金奖1项, ,,, ,,,省部级一等奖3项。。。。。。。

    空间探索、煤矿搜救、核电运维等领域的情形重大、工况极端、使命多样, ,,, ,,,古板牢靠构型机械人难以胜任。。。。。。。模??? ?榛等四芄煌üノ荒???? ?榧涞淖楹稀⒉鸱质迪止剐偷闹匦律柚, ,,, ,,,构乐成能各异的机械人, ,,, ,,,在使命顺应性、功效扩展性和容错与自修复性等方面具有显著优势。。。。。。。报告首先对模??? ?榛等耸忠站傩屑蛞母攀, ,,, ,,,然后先容了本团队开展的相关研究, ,,, ,,,包括模??? ?樯杓啤⒏兄搿⒅毓棺樽啊⒃硕⒐收险锒嫌肴荽硇薷吹, ,,, ,,,这些研究效果批注, ,,, ,,,模??? ?榛等嗽谥卮笄樾魏褪姑芯哂辛衫挠τ迷毒。。。。。。。

  • 首页- 优德官网集团(中国)有限公司
    Sabine Hauert
    Associate Professor at University of Bristol
    Swarms for people

    Sabine Hauert is Associate Professor (Reader) of Swarm Engineering at University of Bristol. She leads a team of 20 researchers working on making swarms for people, and across scales, from nanorobots for cancer treatment, to larger robots for environmental monitoring, or logistics (https://hauertlab.com/). Before joining the University of Bristol, Sabine engineered swarms of nanoparticles for cancer treatment at MIT, and deployed swarms of flying robots at EPFL. Her recent work has been published in Science Robotics, Science Advances, Advanced Intelligent Systems, Nature Machine Intelligence, and ICRA/IROS and Ra-L. She’s PI or Co-I on more than 20M GBP in grant funding and has served on national and international committees, including the UK Robotics Growth Partnership, the Royal Society Working Group on Machine Learning and Data Community of Interest, and several IEEE boards. She is President and Executive Trustee of non-profits robohub.org and aihub.org, which connect the robotics and AI communities to the public. As an expert in science communication, she is often invited to speak with media and at conferences (over 50 invited talks).
    As tiny robots become individually more sophisticated, and larger robots easier to mass produce, a breakdown of conventional disciplinary silos is enabling swarm engineering to be adopted across scales and applications, from nanomedicine to treat cancer, to cm-sized robots for large-scale environmental monitoring or intralogistics. This convergence of capabilities is facilitating the transfer of lessons learned from one scale to the other. Cm-sized robots that work in the 1000s may operate in a way similar to reaction-diffusion systems at the nanoscale, while sophisticated microrobots may have individual capabilities that allow them to achieve swarm behaviour reminiscent of larger robots with memory, computation, and communication. Although the physics of these systems are fundamentally different, much of their emergent swarm behaviours can be abstracted to their ability to move and react to their local environment. This presents an opportunity to build a unified framework for the engineering of swarms across scales that makes use of machine learning to automatically discover suitable agent designs and behaviours, digital twins to seamlessly move between the digital and physical world, and user studies to explore how to make swarms safe and trustworthy. Such a framework would push the envelope of swarm capabilities, towards making swarms for people.

Time Session Speaker&Topic

15:00-15:45

Keynote Speech

朱延河, 哈尔滨工业大学
Topic: 面向重大情形和使命的模??? ?榛灾鞅湫位等

15:50-16:35

Keynote Speech

Sabine Hauert, University of Bristol
Topic: Swarms for people

Video Archive